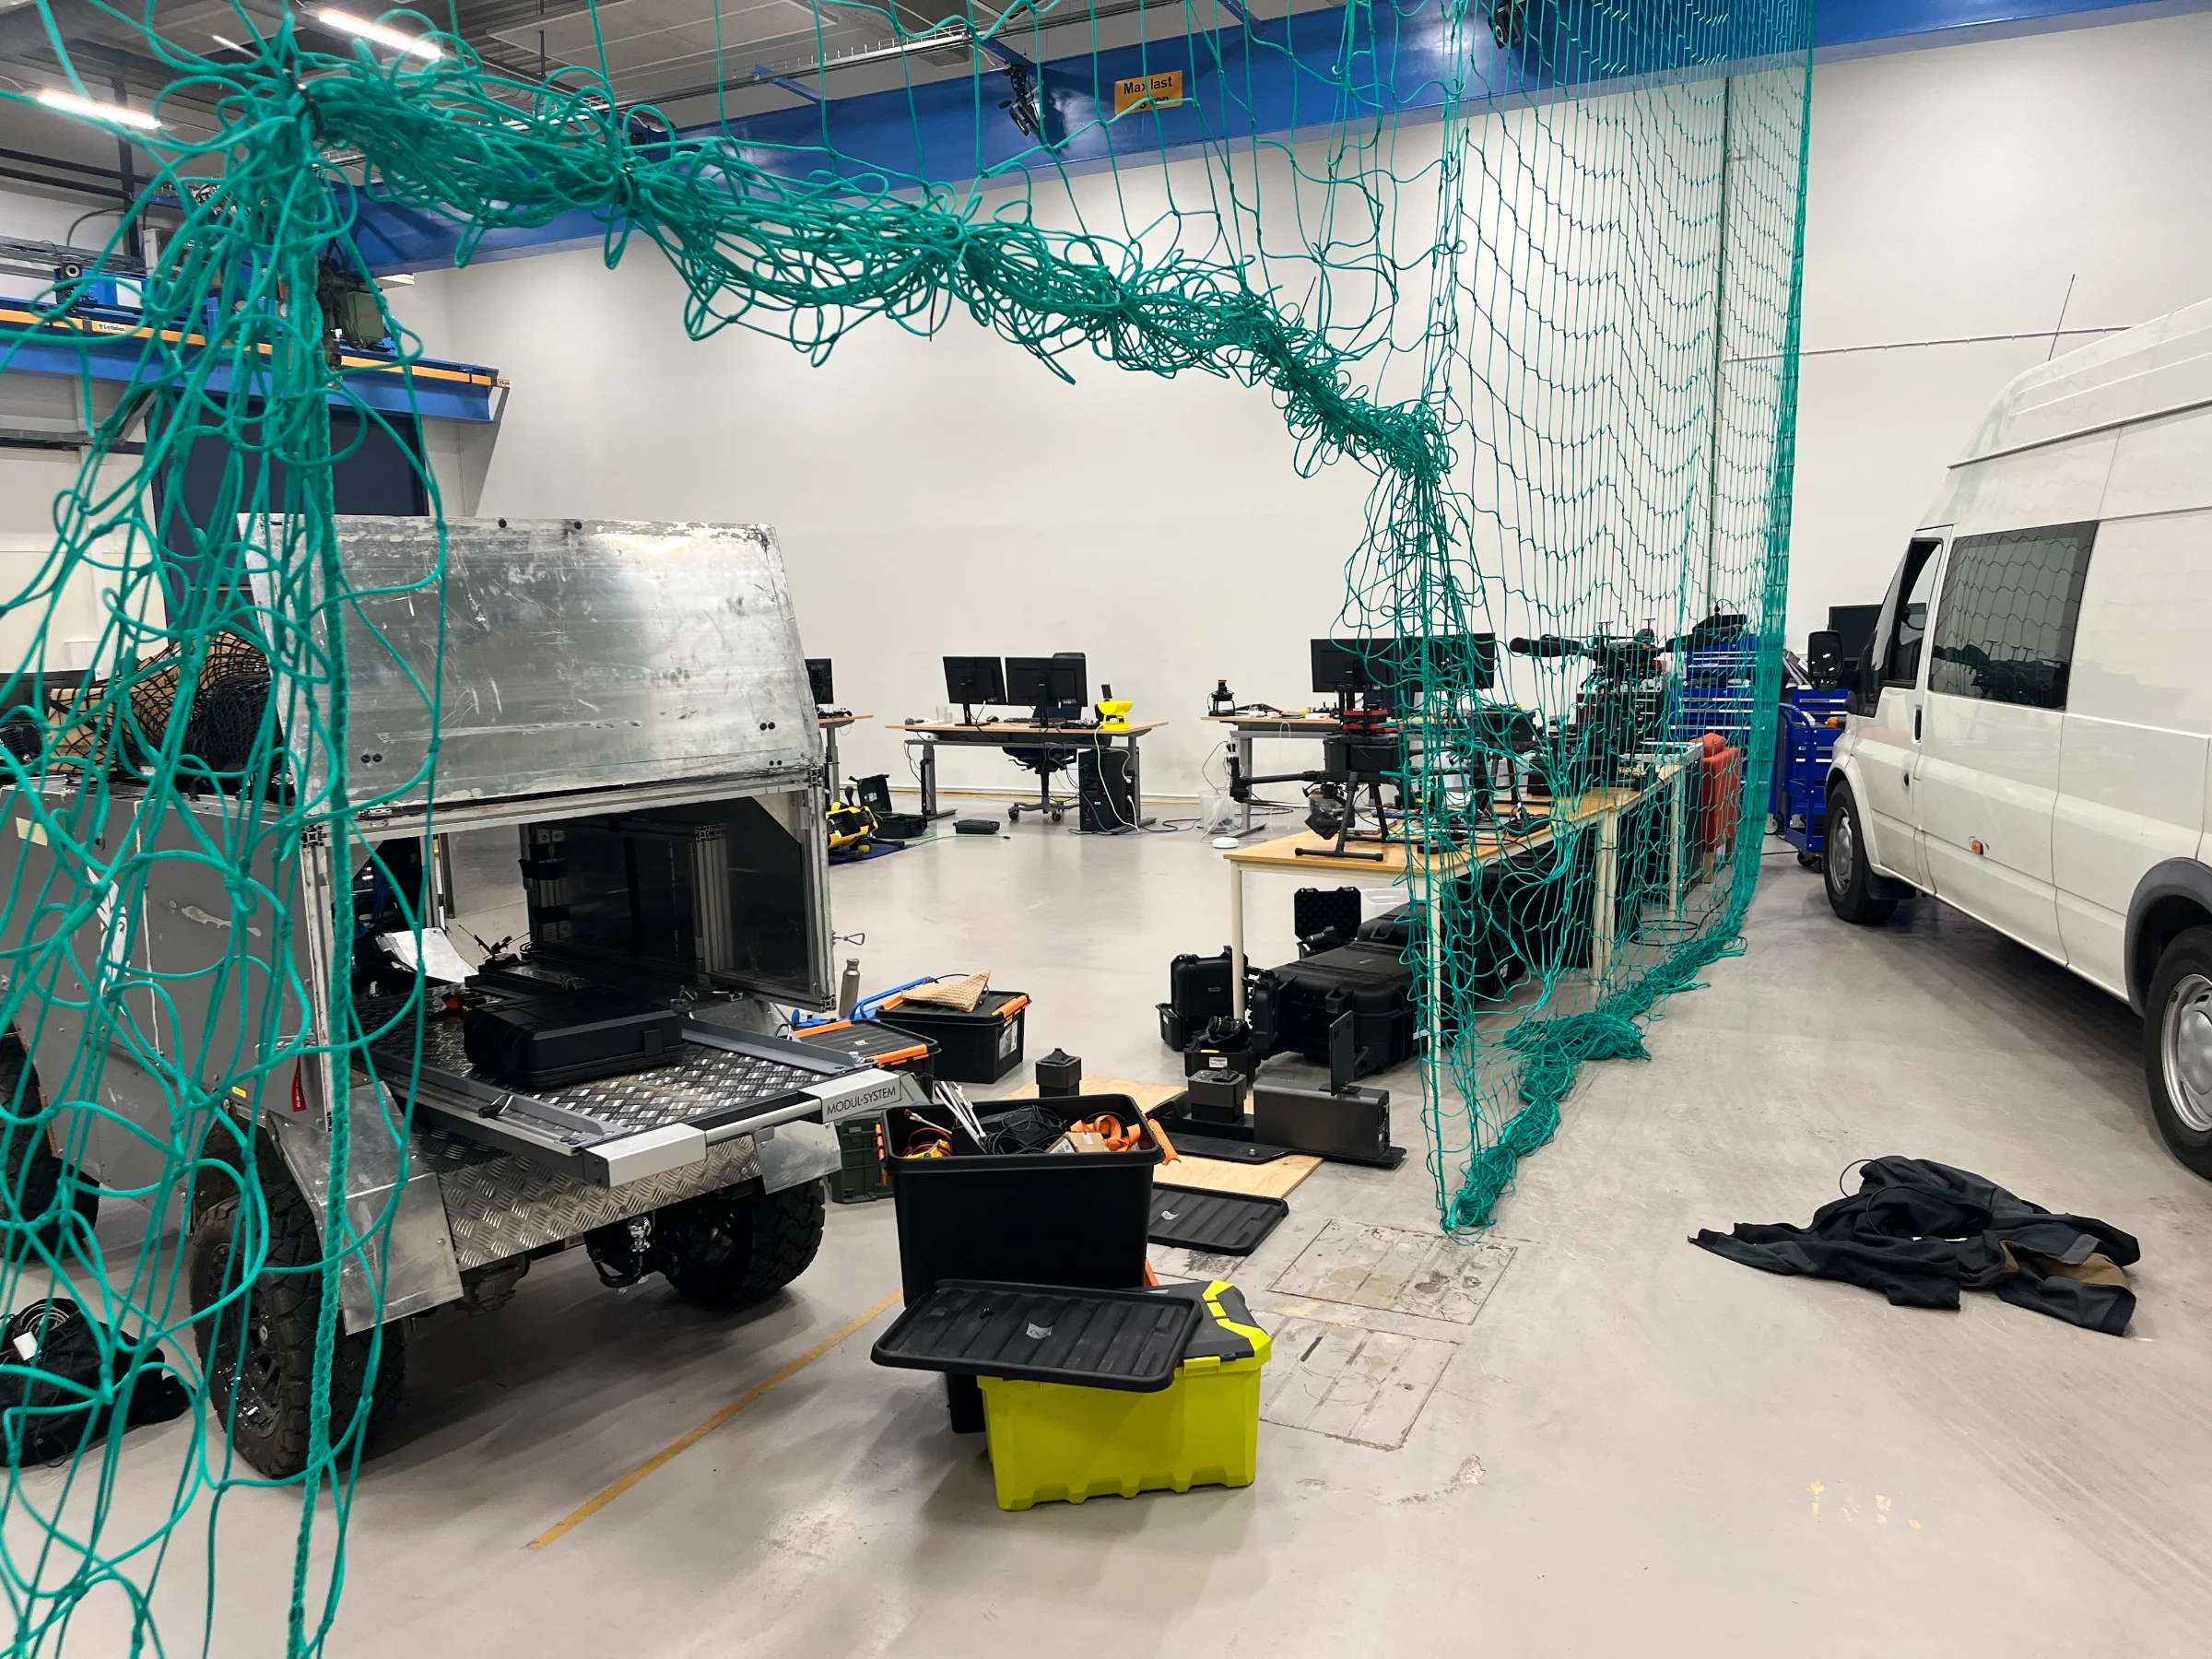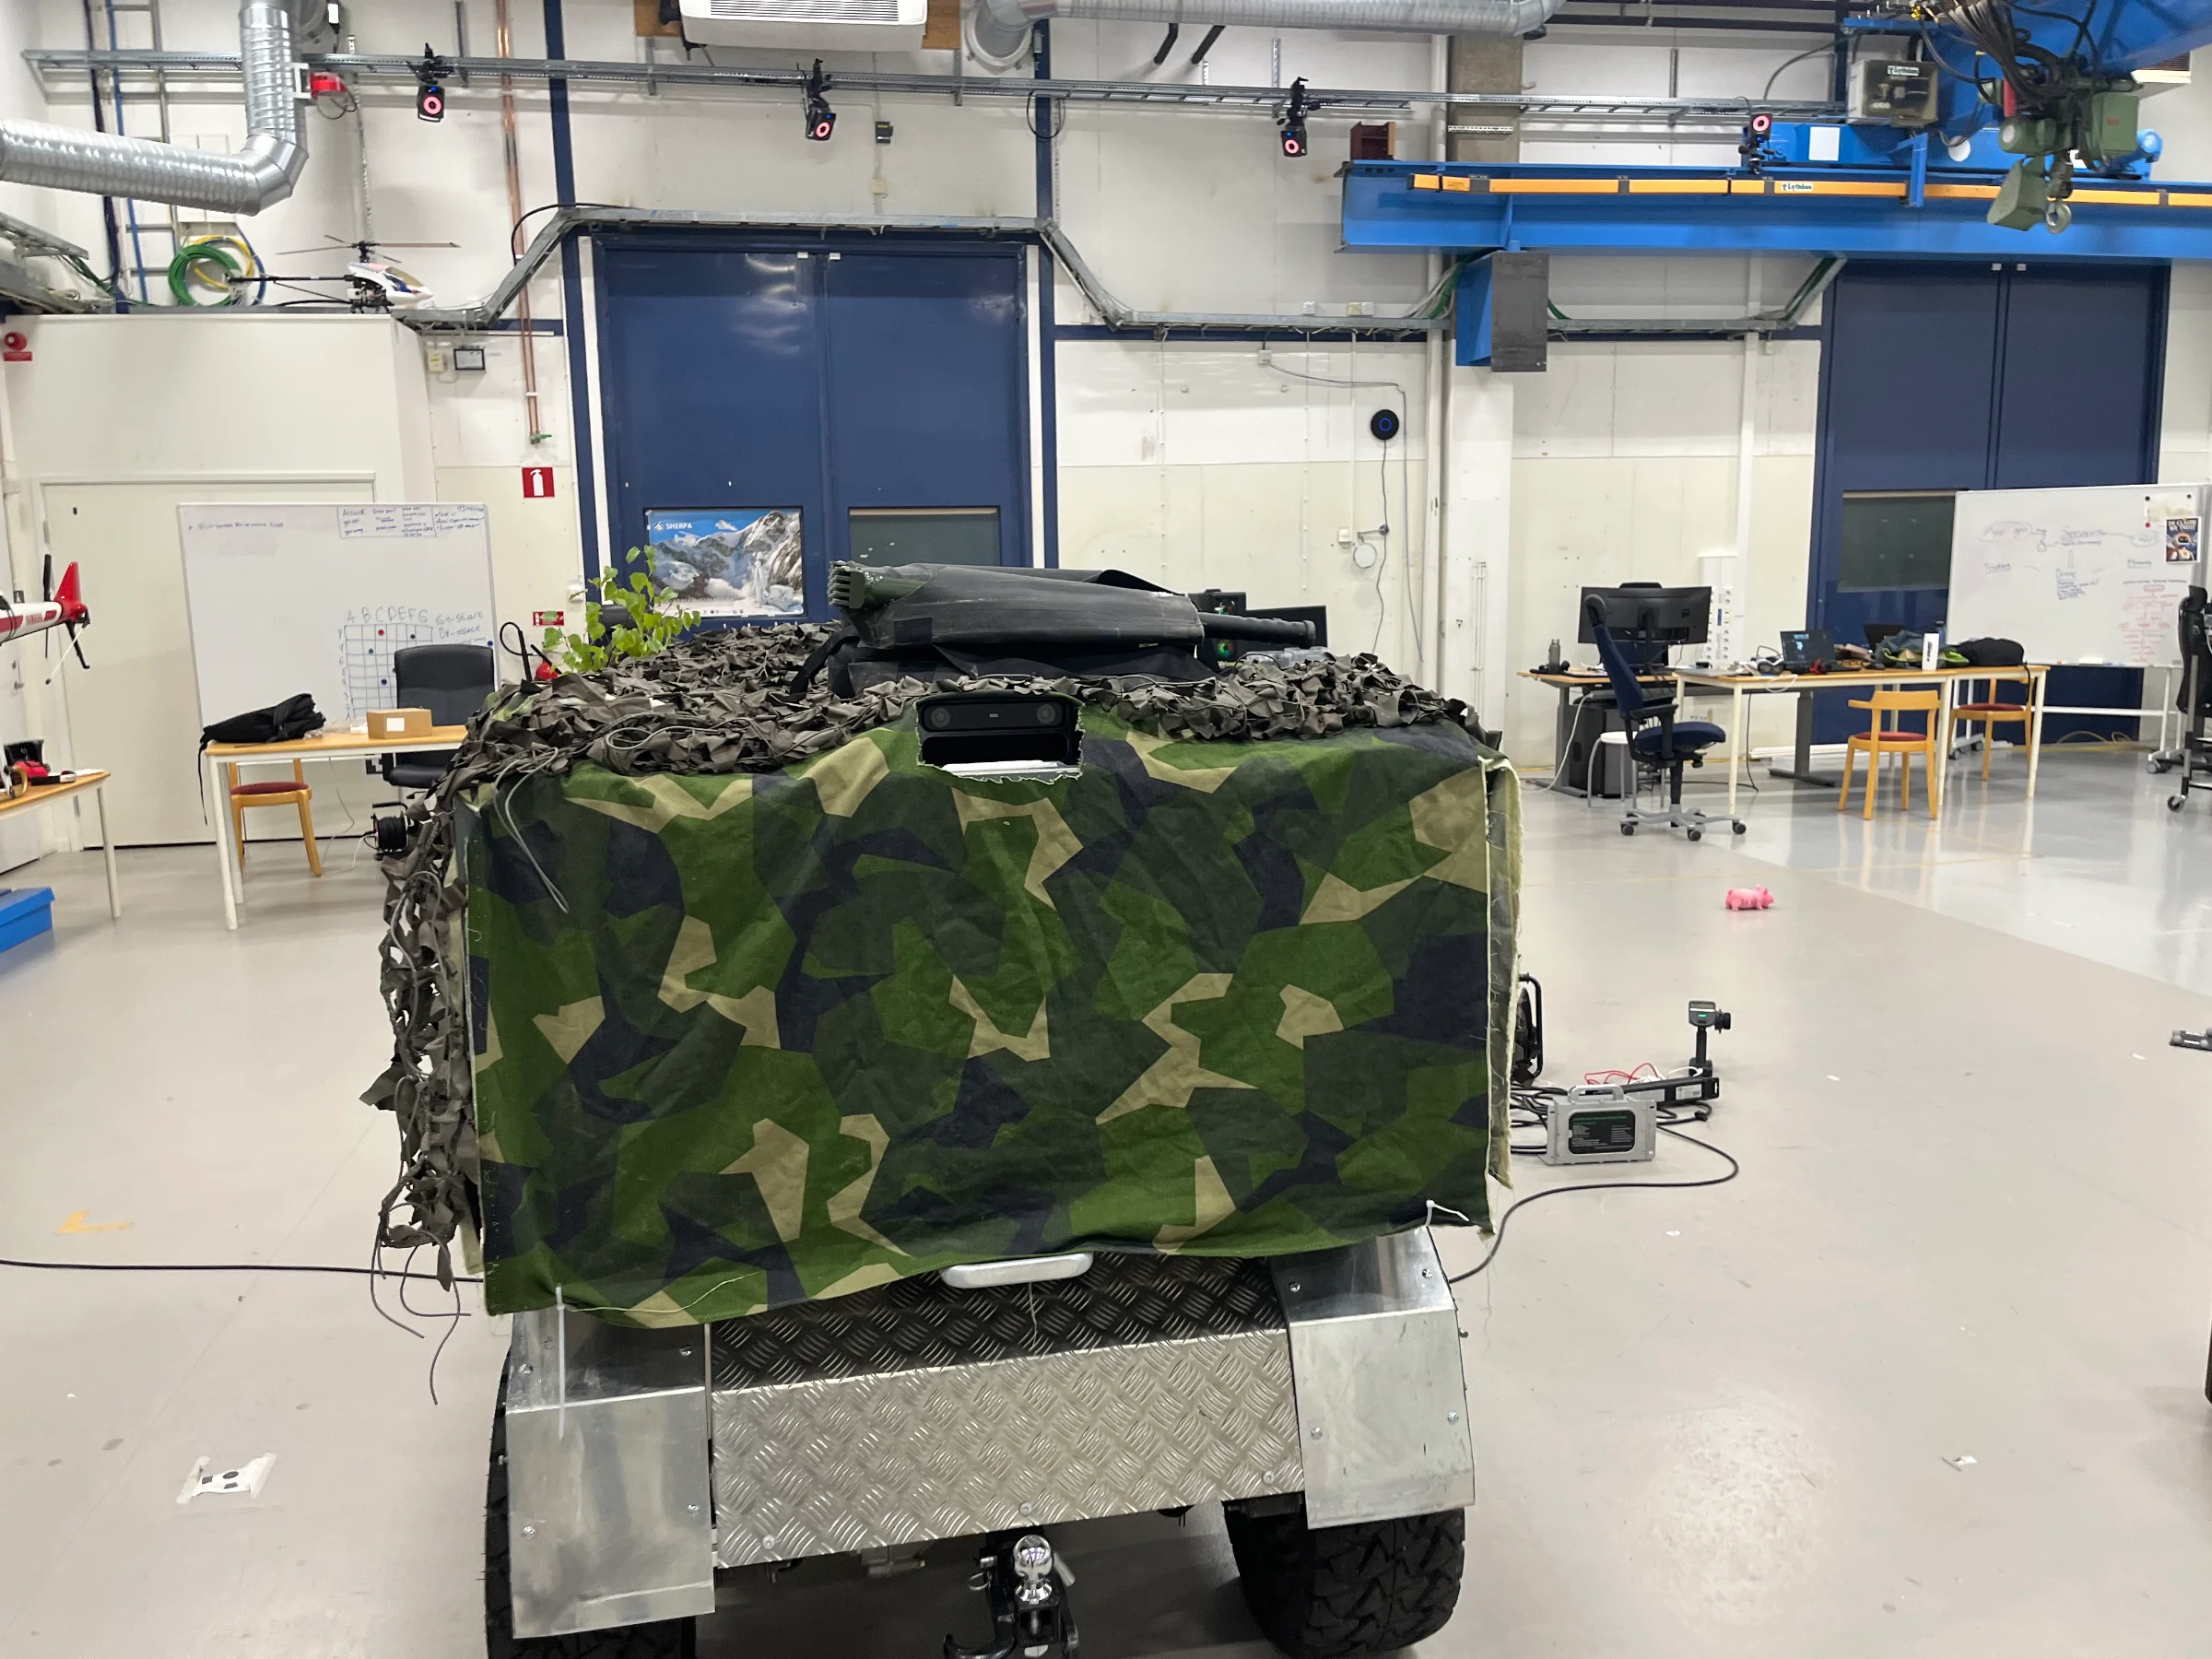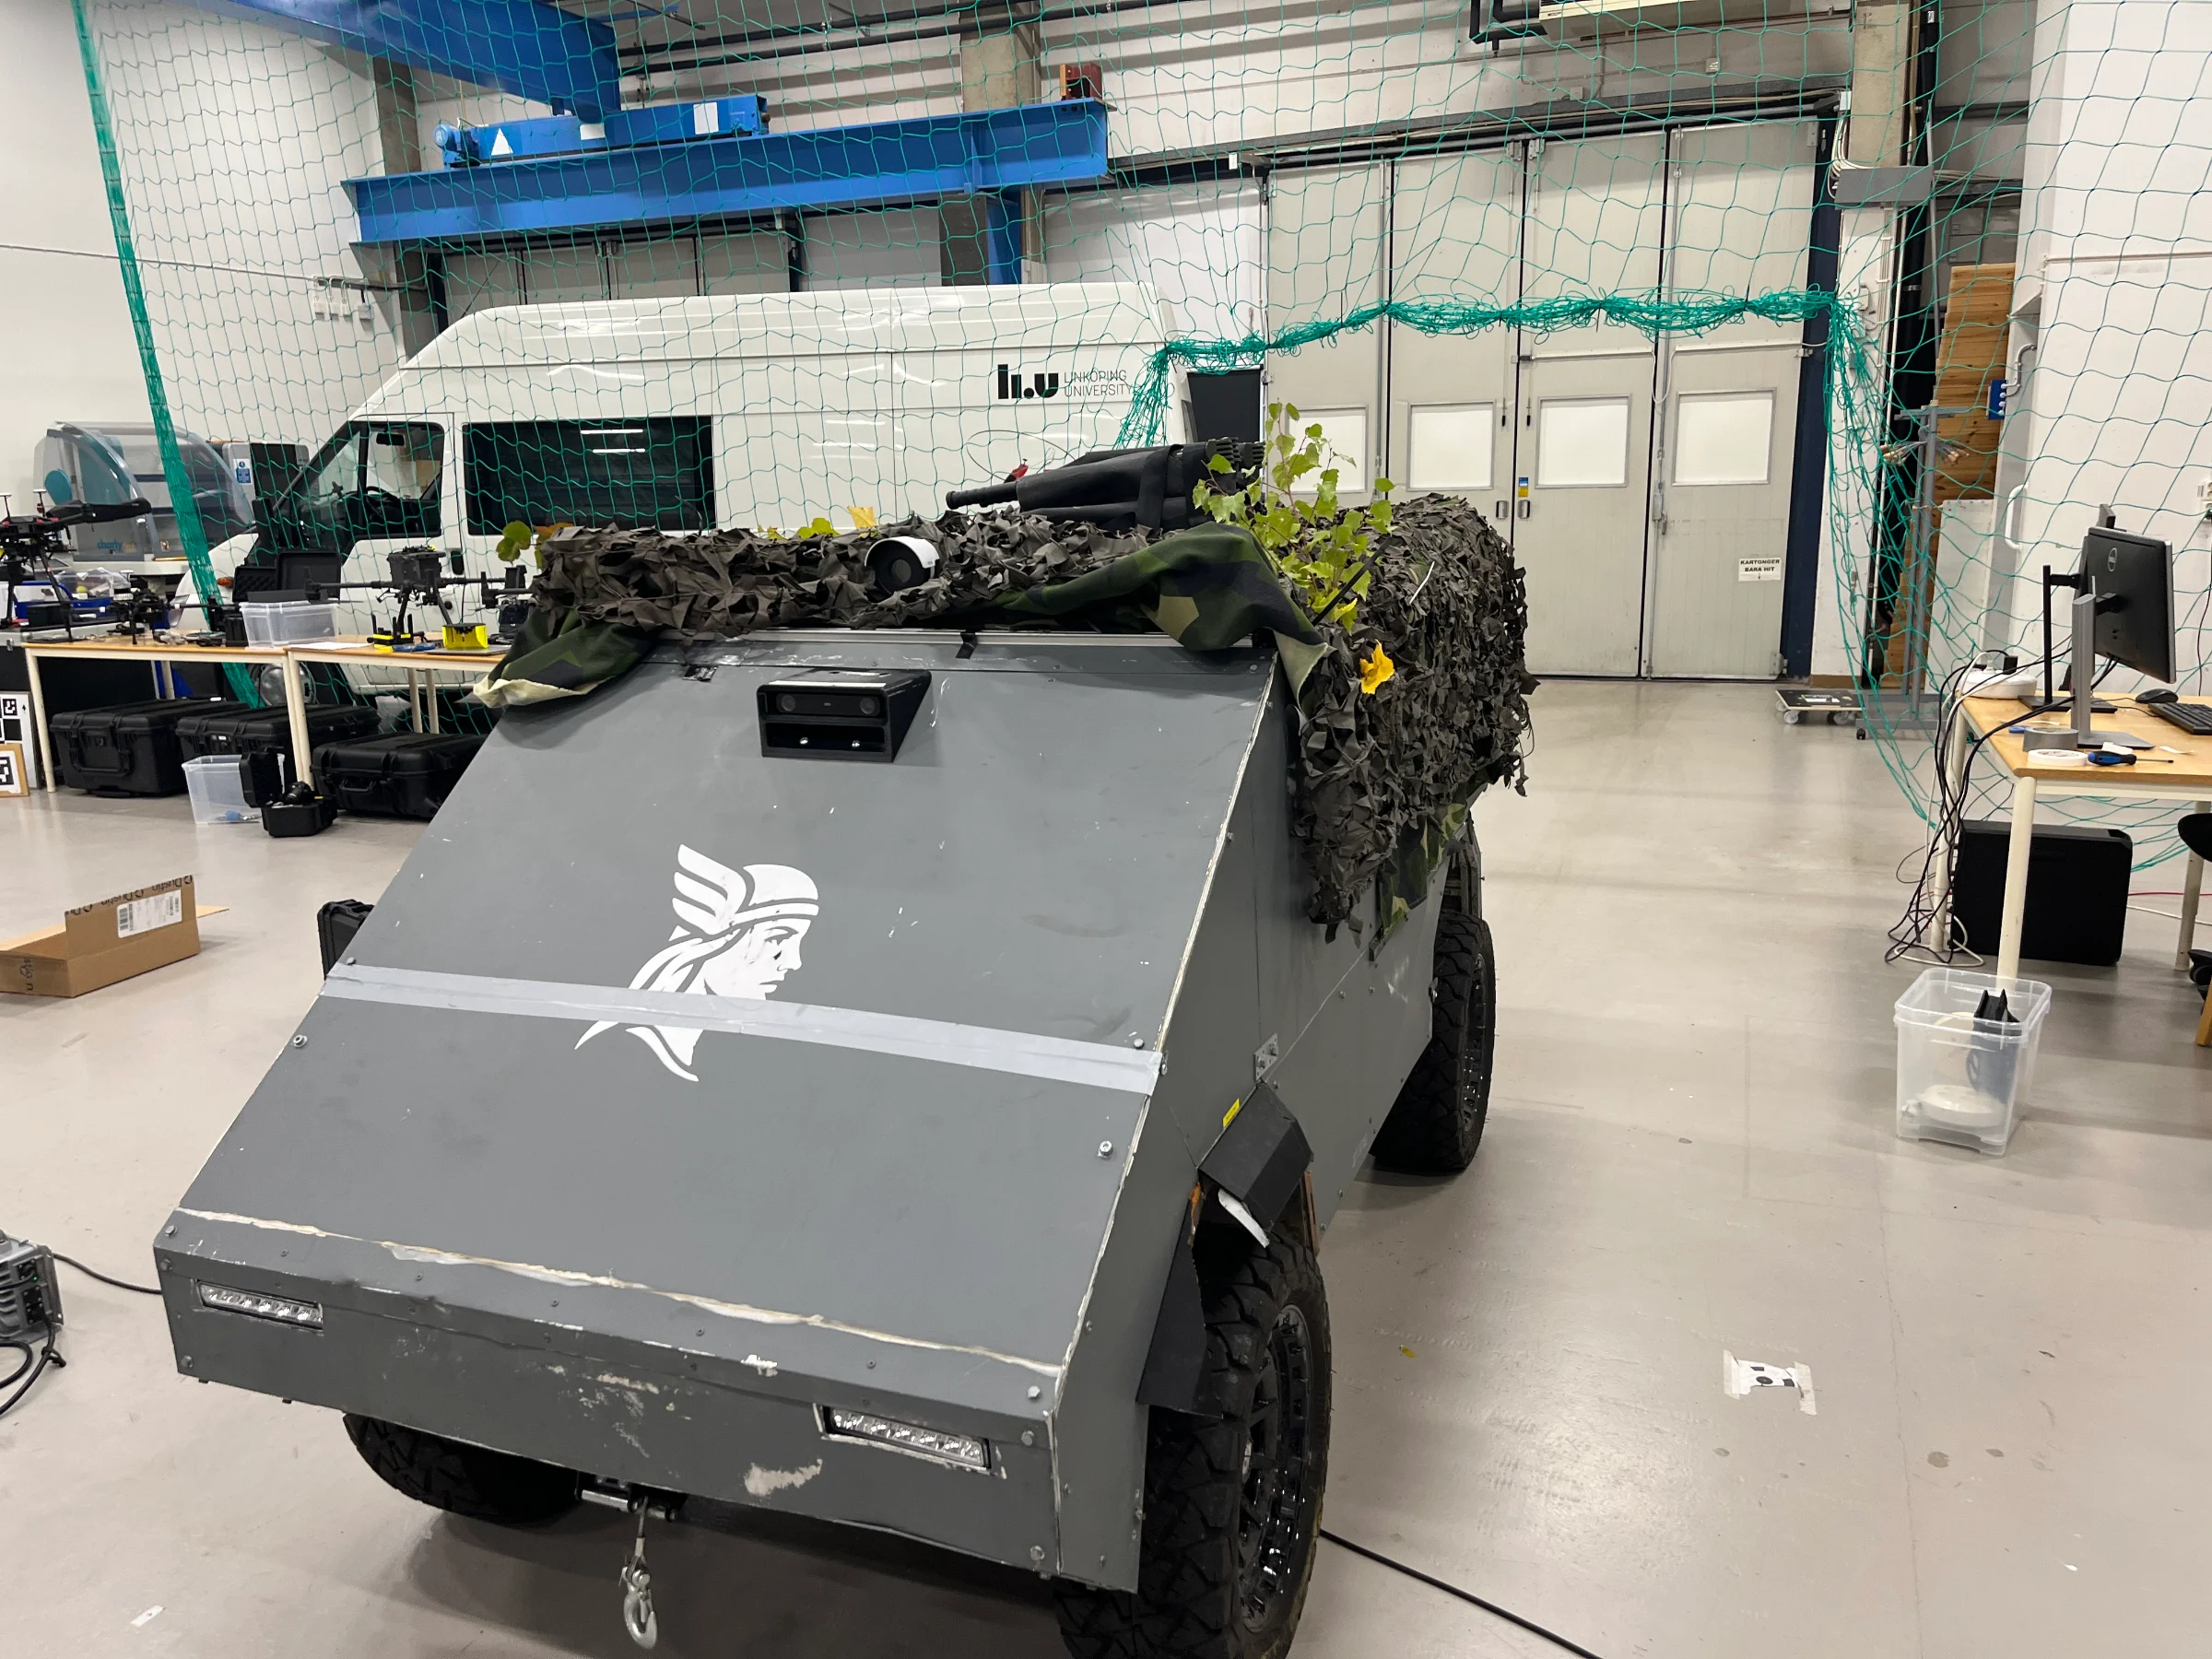
In Linköping, we competed in the EUDIS Defence Hackathon. Our focus was GNSS-denied navigation. We tested using only visual-inertial odometry for pose estimation to see how well we could track without wheel encoders, enabling wheel-slip-independent navigation off-road.
We navigated outside the Terra lab building at Linköping University. We also worked on our backtrack and path-following capabilities. We managed several longer backtracks partly on off-road terrain, as well as some really tricky ones reversing out of the lab, see videos below.
The left video shows autonomous driving, while the right shows manual operation. It was quite tricky to drive manually, but Eira handled it really well on her own.
We also used our 3D reconstruction pipeline to do reconnaissance of the area we operate in.
We also improved our remote operations performance for this event.
Special thanks to Piotr and Mariusz for their time and allowing us to use their lab.